Selected Research Projects
Click on any project to learn more about the methodology and results.
(Project pages currently under construction, stay tuned for the latest versions)
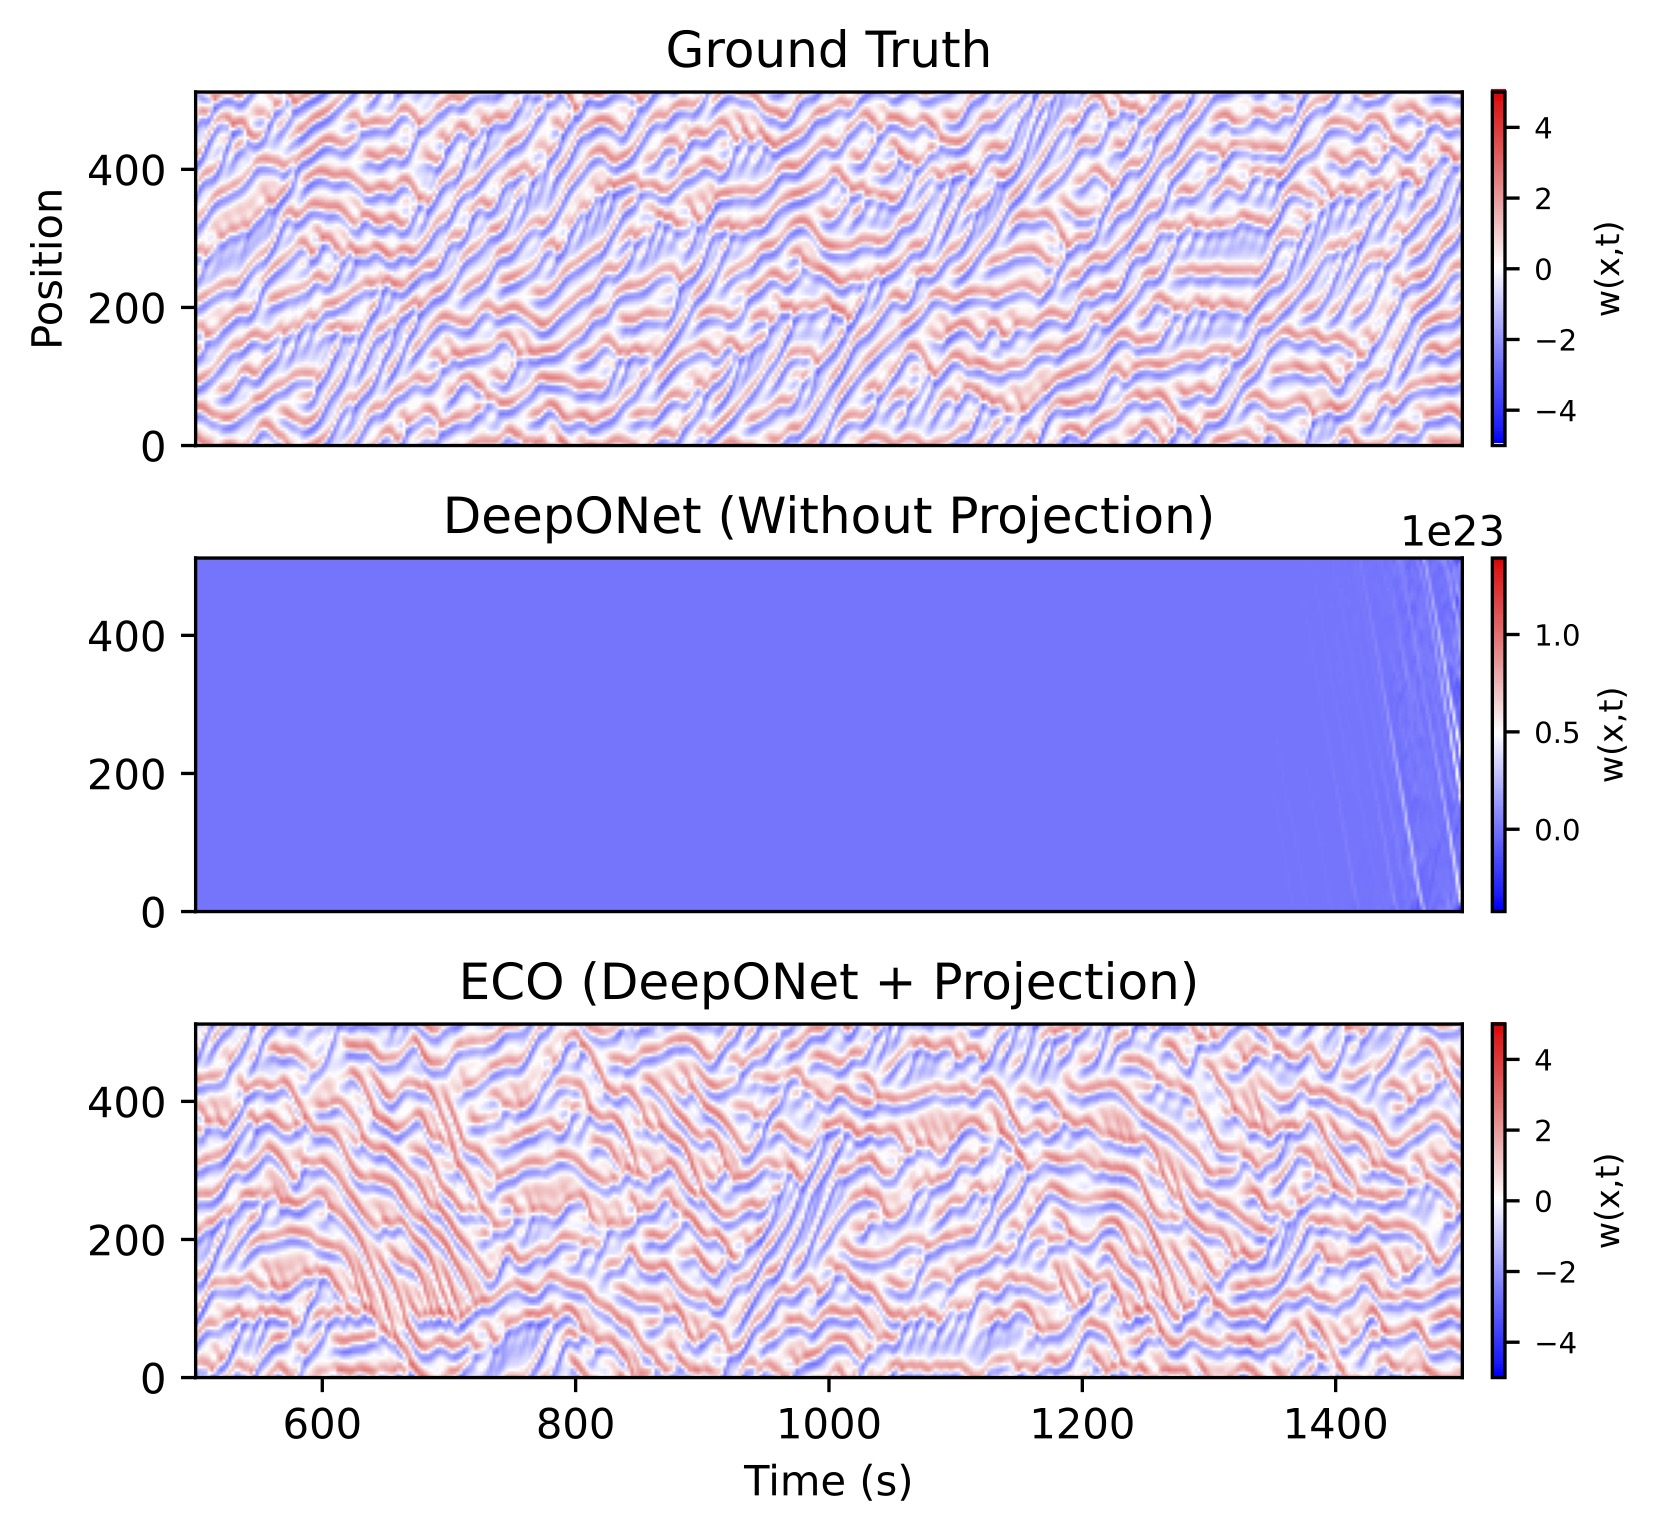
ECO: Energy-Constrained Operator Learning for Chaotic Dynamics with Boundedness Guarantees
Andrea Goertzen*, Sunbochen Tang*, Navid Azizan (*equal contribution)
L4DC 2026 — Best Paper Award
A novel framework for learning chaotic dynamics with hard stability guarantees, ensuring that long-term predictions remain stable and physically plausible by enforcing dissipative constraints.
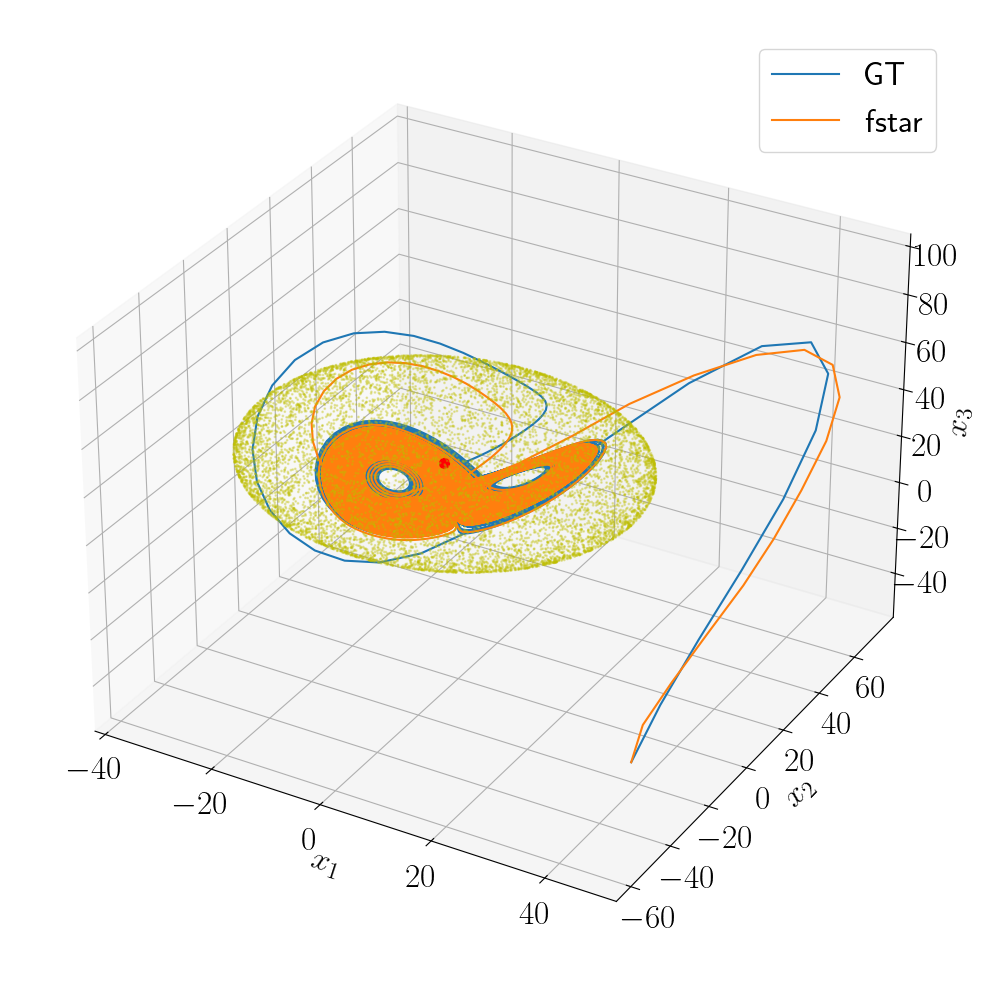
Learning Dissipative Chaotic Dynamics with Stability Guarantees
Sunbochen Tang, Themistoklis Sapsis, Navid Azizan
Accepted to the Proceedings of the National Academy of Sciences (PNAS)
A continuous-time formulation for learning dissipative chaotic dynamics as ODEs with boundedness guarantees. Examples include Lorenz 63, 96, and the Kuramoto-Sivashinsky system.
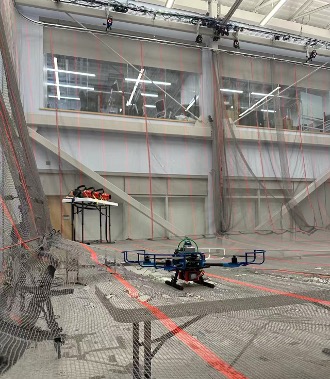
Meta-Learning for Adaptive Control with Automated Mirror Descent
Sunbochen Tang, Haoyuan Sun, Navid Azizan
L4DC 2025 — Oral Presentation, Best Paper Award Nominee
A meta-learning framework for adaptive control that enables quadrotors to adapt to unknown disturbances rapidly while optimizing mirror descent adaptation law according to geometry embedded in the data.